About Me
I am a PhD student @ General Robotics Lab - Duke (MEMS), advised by Dr. Boyuan Chen, where I am currently working on field robotics with multi-agent systems, aiming to enable robust collective intelligence in uncertain environments.
I hold an MPhil & a BEng (1st Hons) from Hong Kong PolyU (AAE). My research/studies were fully funded via Presidential Research Fellowship & APEC Scholarship. I also did an academic exchange at UQ Australia (AE).
Previously, I was a member @ AIRO Lab mentored by Prof. Chih-Yung Wen & Dr. Boyang Li. I also worked as a RA @ HKCRC, a research institute led by Prof. Zexiang Li.
Up'til now, my focus has been on UAVs, UGVs, UUVs, & multi-agents (homo/heterogeneous), with experiences in v-SLAM, traj-opt, MPC, Lyapunov-based control & dynamics. Feel free to ping me for discussions if any of the above interests you; my RTT is usually low :)
Projects
HARP: Modular Aerial-Ground Reconfigurable Platform [Code] [PDF]
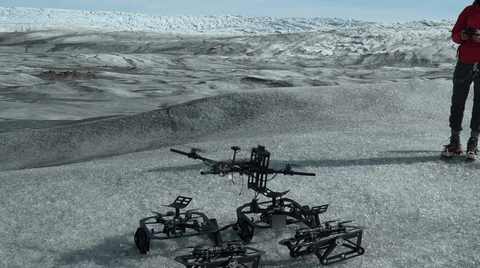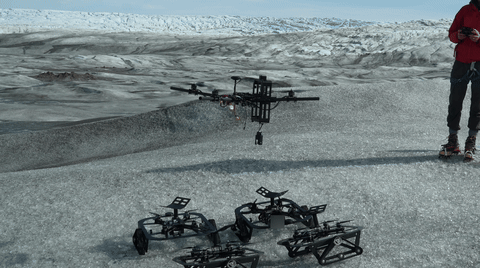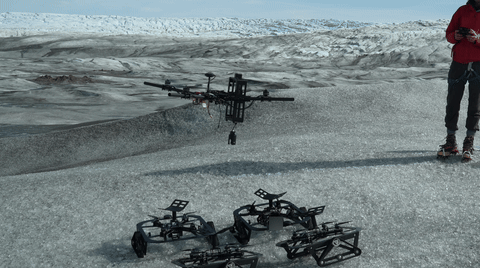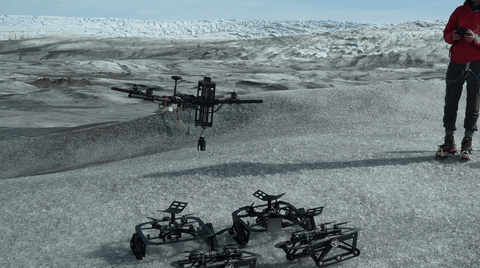
† Co-first authors.
MARBLE: Omnidirectional Amphibious Locomotion [Code] [PDF]
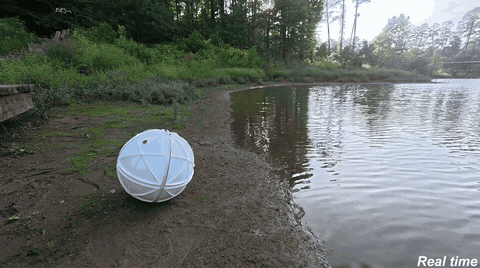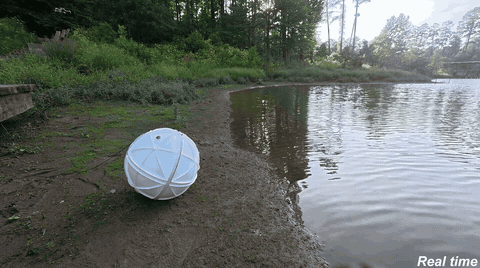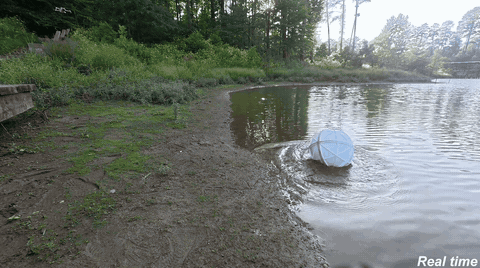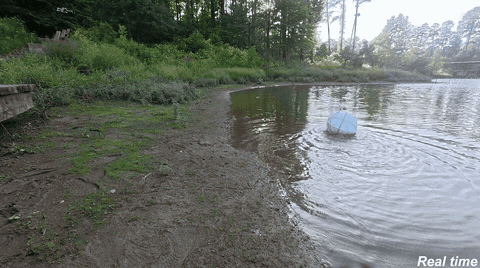
† Co-first authors.
SonicFly: Aeroacoustic Sensing and Pursuit [Code] [PDF]
Non-Robocentric Dynamic Landing of Quadrotor [Code] [PDF] [Link]
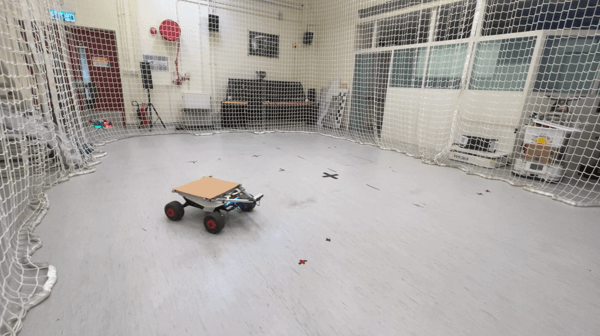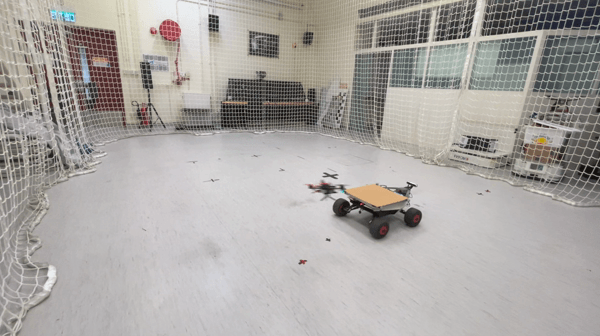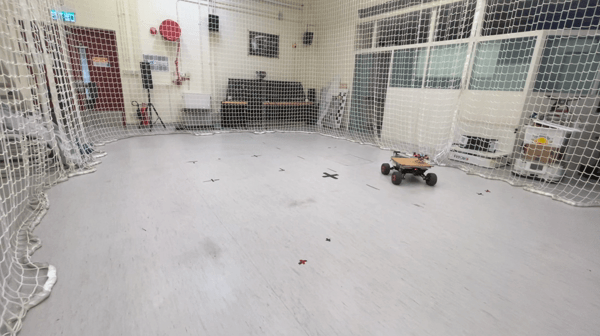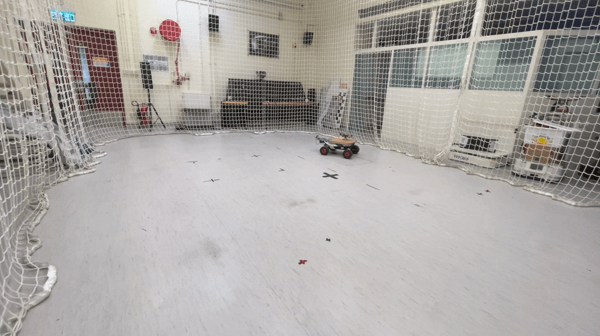
Adaptive Model Predictive Control [Code] [PDF] [Link]
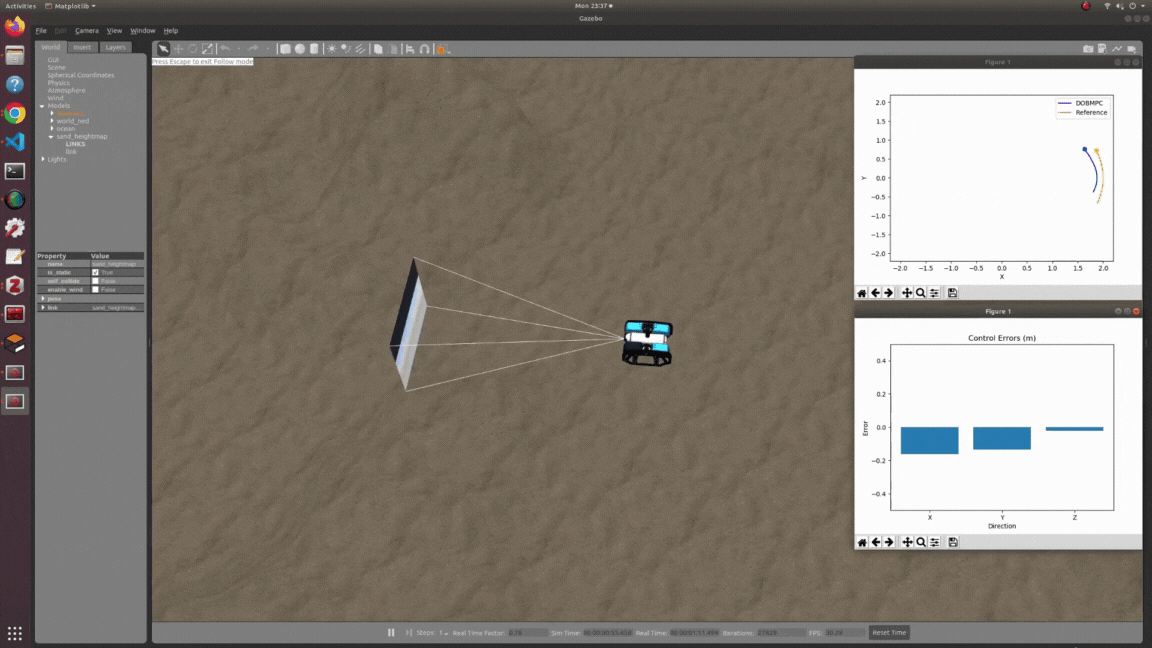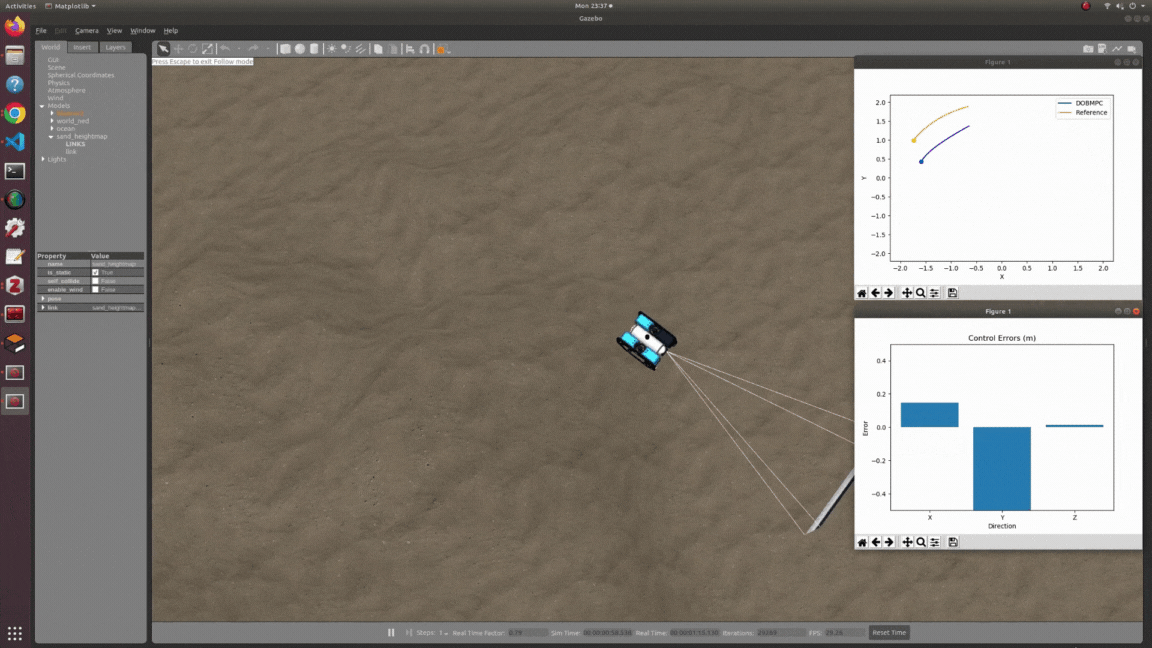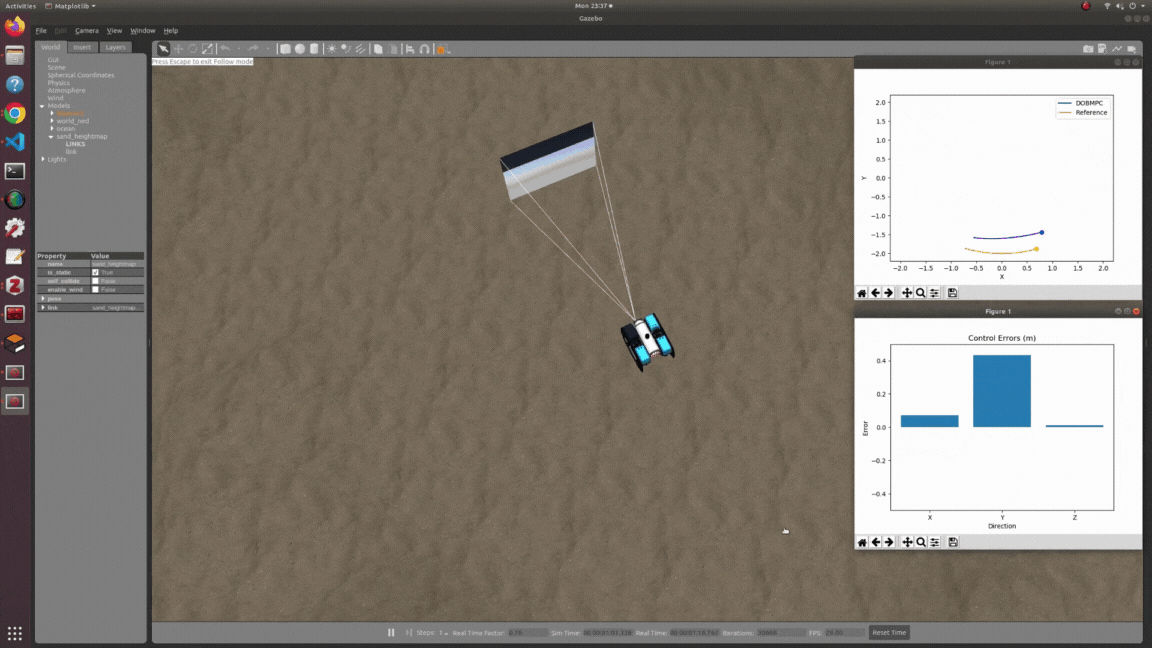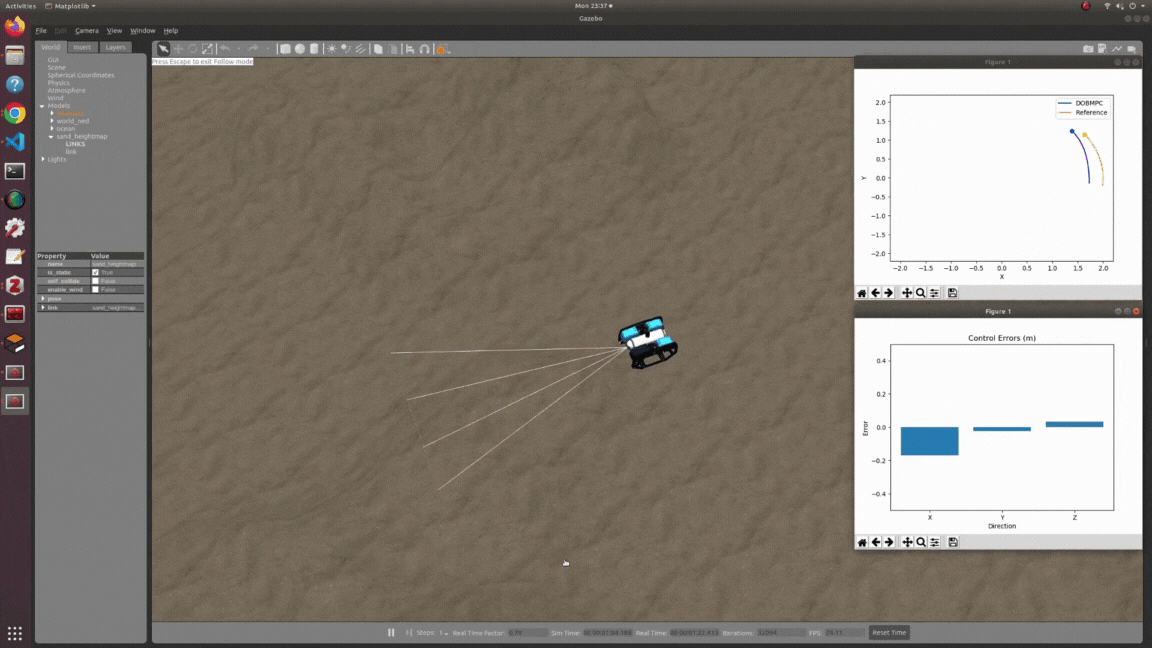
Nonlinear Control with ADP (RL) Optimizer [PDF] [link]
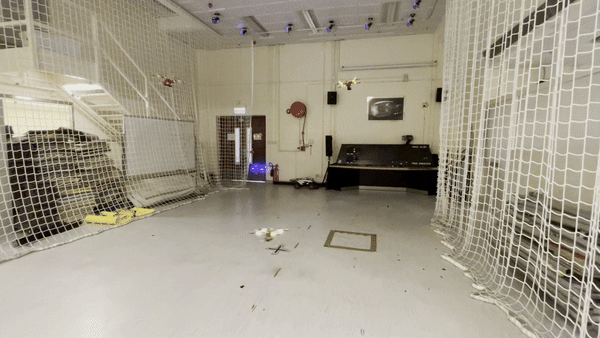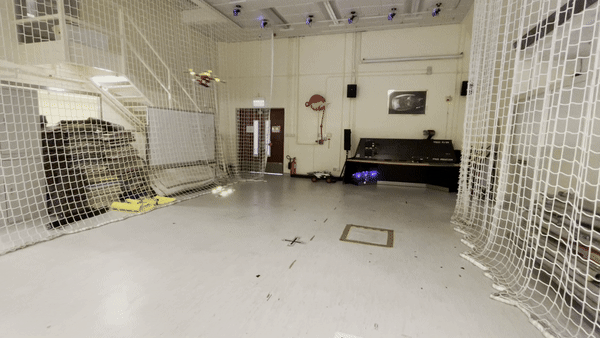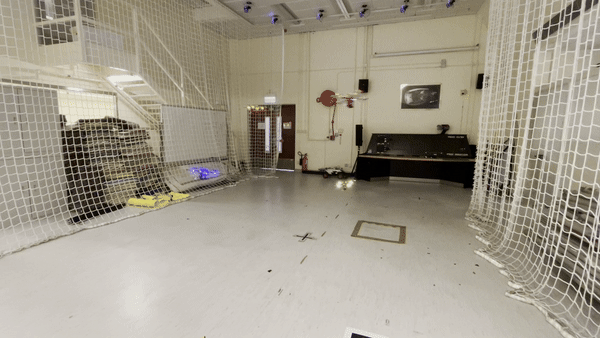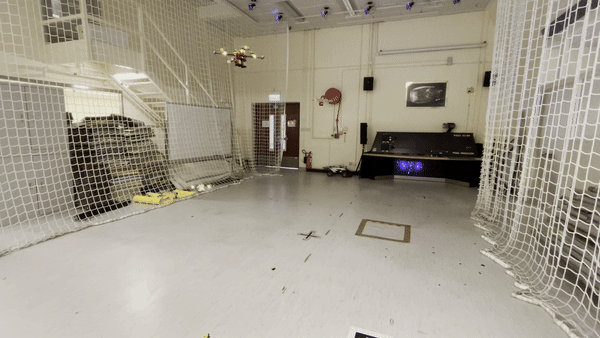
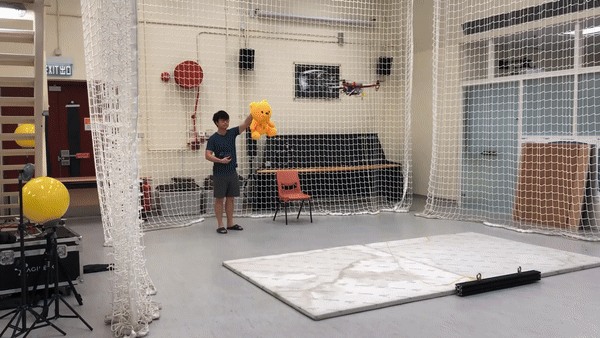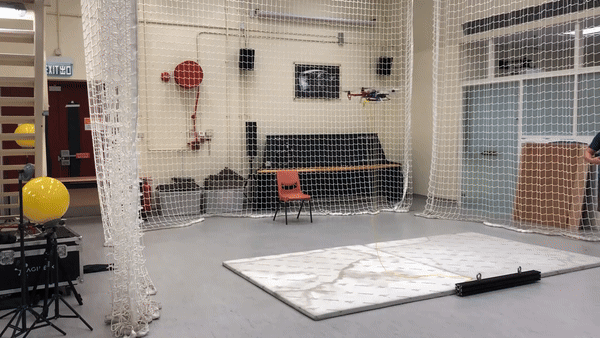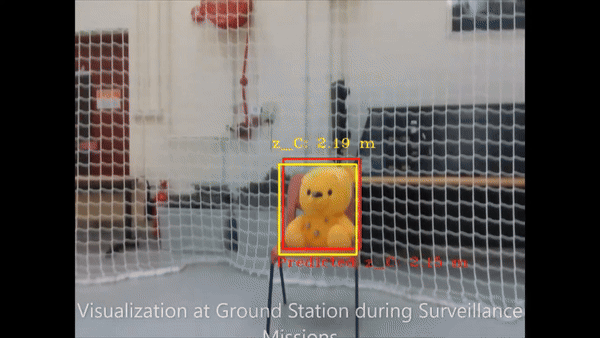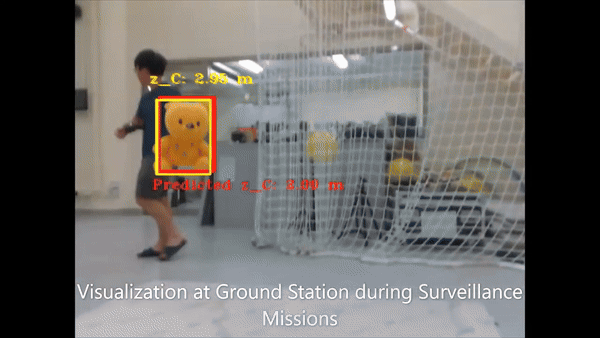
Dynamic Object Tracking with Quadrotor [Code] [PDF] [Link]
Fun
A Bootcamp for Legged Robotics via Biped and Quadruped Simulation [Code]
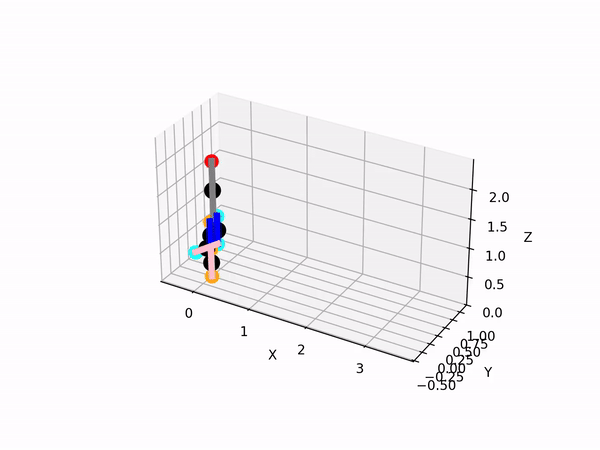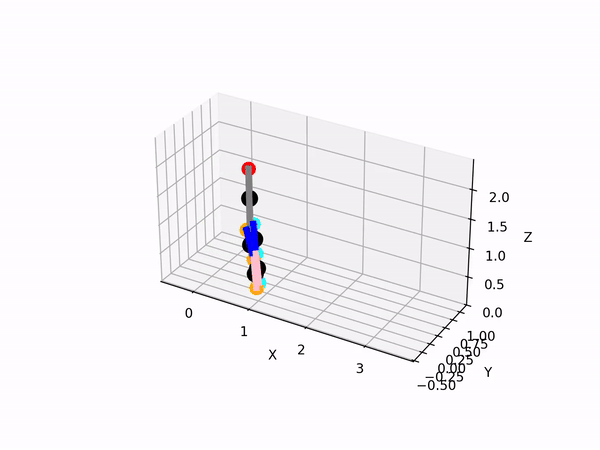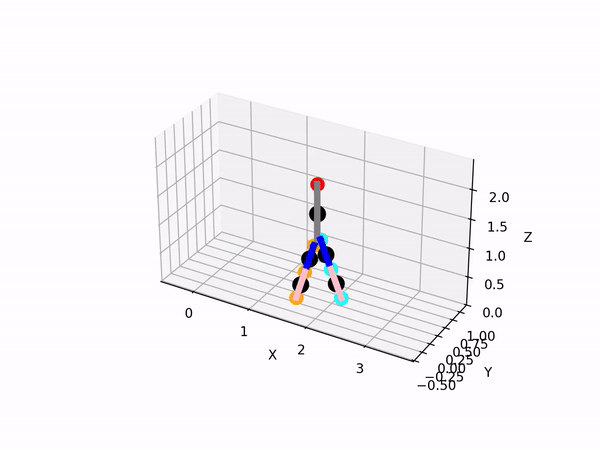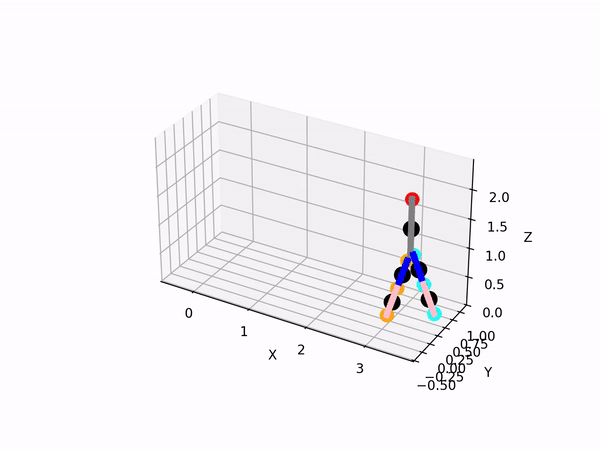
Bipedal Robot Design with Duke Robot Studio [Code]
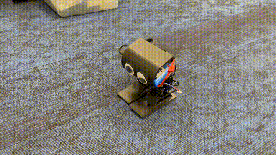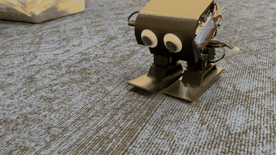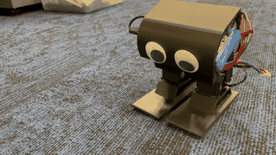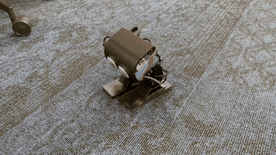
Toy Convex Solver [Code] [PDF]
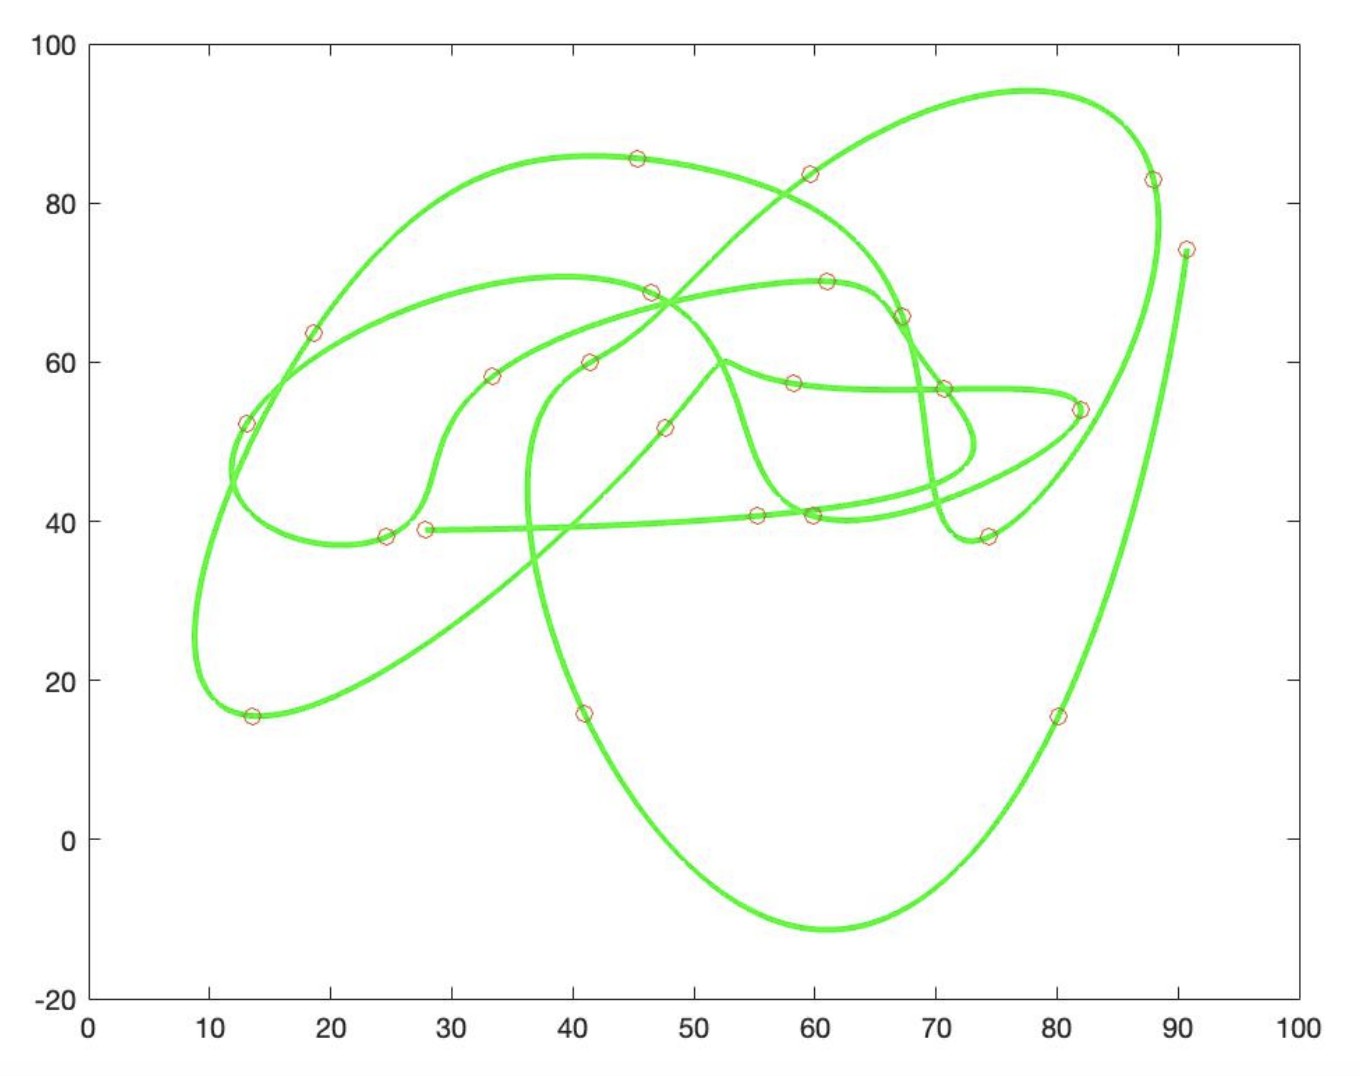
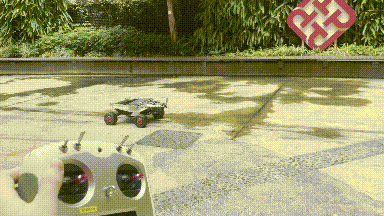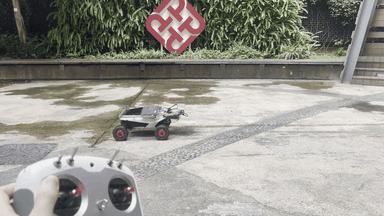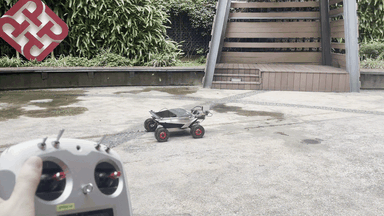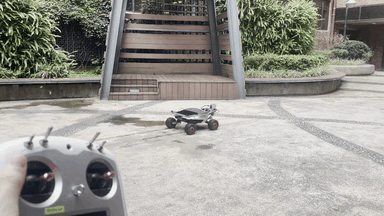
An Autonomous UGV with LOAM [Code-SITL] [Code-Firmware]
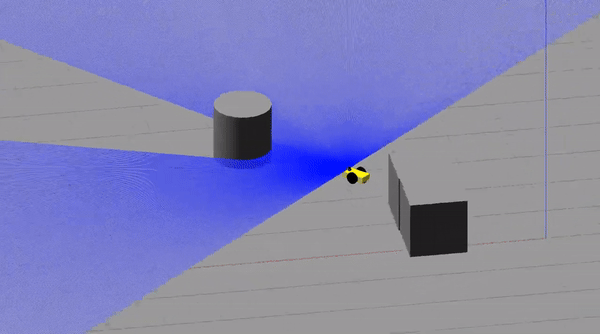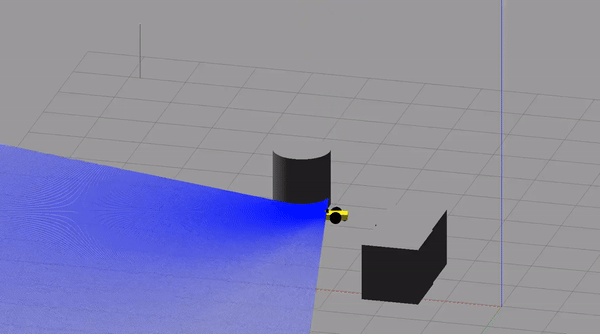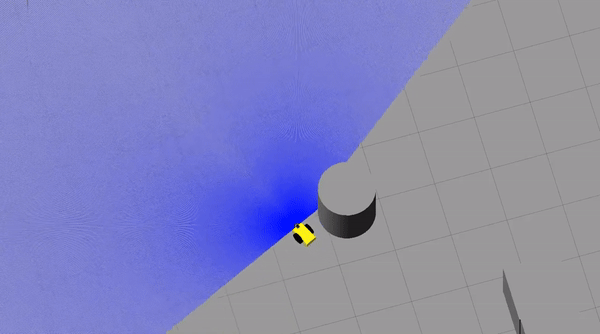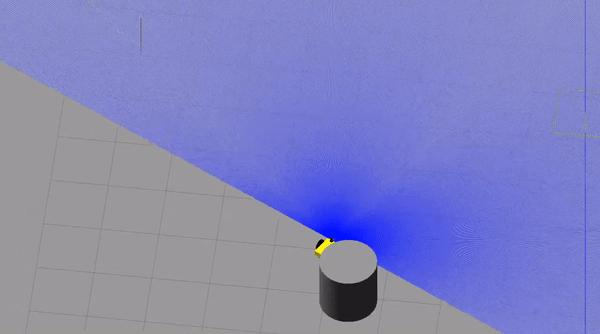
Bug Planner Implementation for Nonholonomic Planner Robots [Code]
Detailed Pub List
- L.-Y. Lo, B. Li, C.-Y. Wen, and C.-W. Chang, “Experimental Non-Robocentric Dynamic Landing of Quadrotor UAVs with On-Ground Sensor Suite,” IEEE Transactions on Instrumentation and Measurement (TIM), vol. 73, 2024. [link]
- L.-Y. Lo, Y. Hu, B. Li, C.-Y. Wen, and Y. Yang, “An adaptive model predictive control for unmanned under-water vehicles subject to external disturbances and measurement noise,” in 2024 14th Asian Control Conference (ASCC). IEEE, 2024, pp. 01–07. [link]
- L.-Y. Lo, B. Li, C.-Y. Wen, and C.-W. Chang, “Landing a quadrotor on a ground vehicle without exteroceptive airborne sensors: A non-robocentric framework and implementation,” in 2023 IEEE 26th International Conference on Intelligent Transportation Systems (ITSC). IEEE, 2023, pp. 6080–6087. [link]
- L.-Y. Lo, C. H. Yiu, Y. Tang, A.-S. Yang, B. Li, and C.-Y. Wen, “Dynamic object tracking on autonomous uav system for surveillance applications,” Sensors, vol. 21, no. 23, p. 7888, 2021. Editor’s Choice Article. [link]
- Y. Yang, K. Liu, L.-Y. Lo, T. Huang, Y. Fu, and C.-Y. Wen, “Fixed-time adaptive consensus control for multi-quadrotor subject to external disturbances via deep reinforcement learning,” Aerospace Science and Technology (AST), p. 111133, 2025. [link]
- W. Yang, Z. Tan, L.-Y. Lo, K. Liu, and C.-Y. Wen. “Hierarchical 3D scene graph based metric semantic slam for object mapping and counting,” IEEE Internet of Things Journal, 2025. [link]